Quick answer
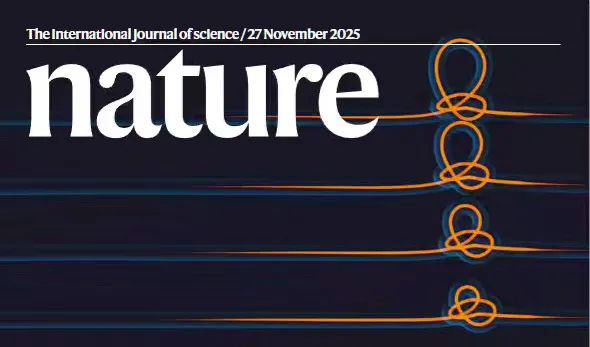
Surgical knots are tied by feel. Too loose and the tissue leaks or the anastomosis fails; too tight and the tissue is strangulated and heals poorly. In open surgery the surgeon's fingers judge this directly. In laparoscopic and robotic surgery that judgment is largely lost — the widely described problem of force blindness. Cai Xiujun's team at Sir Run Run Shaw Hospital and Yang Wei's cross-disciplinary mechanics centre at Zhejiang University spent three years on a deceptively simple solution: put a precisely engineered slipknot beside the surgical knot, so that untying it delivers a known force. The paper, Sliputure, was the cover article in Nature on 27 November 2025 [1][2][5].
Key takeaways
- Paper: "Slipknot-gauged mechanical transmission and robotic operation", Nature cover article, 27 November 2025 [4].
- Teams: Cai Xiujun and Chen Mingyu at Sir Run Run Shaw Hospital with Yang Wei, Li Tiefeng and Yang Xuxu at Zhejiang University's cross-mechanics centre [2][6].
- Principle: a preset peak force is stored in the slipknot and released at the moment it unties, transmitting force information through the suture line [3][5].
- Development time: three years of interdisciplinary work [2].
- Co-first authors: Xue Yaoting, Cao Jiasheng, Feng Tao and Zhang Kaihang [6].
Why a knot can act as a sensor
The mechanism inverts the usual logic. Instead of adding a force sensor to the instrument — which is expensive, bulky and hard to sterilise — the suture itself carries the calibration. Tying the slipknot with a defined geometry fixes the force at which it will release; when the surgeon tensions the line, that release becomes the reference point against which the working knot's tightness is set [3][5].
That makes it cheap and disposable, and it works with existing instruments and robots rather than requiring a new platform. The paper also argues the underlying mechanics could inform other robotic and smart-structure designs, which is why a mechanics journal-level contribution ended up on the cover of Nature [2][4].
What a cover paper does and does not establish
The result is a mechanism plus a demonstration of surgical and robotic application. That is a genuine advance in surgical instrumentation, and it addresses a problem surgeons have complained about since the first laparoscopic needle holder [1][3].
There is no randomised comparison of anastomotic leaks or wound complications with Sliputure versus conventional knots, and no data on how much of the theoretical benefit survives in the hands of average rather than expert surgeons. The added slipknot must also be cut away and must not leave residual foreign material or a bulky profile in small spaces. Whether a calibrated force actually improves healing depends on what the correct force is for each tissue — and that value is not known for most operations [5][6].
The condition in context: force feedback in surgery
Robotic surgery's loss of haptics is a recognised limitation rather than a marketing point.
| Region | What the data shows | Source |
|---|---|---|
| Open surgery | Hands sense tissue stiffness directly, at the cost of a large incision [3]. | People's Daily health [3] |
| Robotic surgery | High-definition vision and stability, but markedly reduced direct force feedback [3][5]. | People's Daily health [3][5] |
| Consequence | Knot tension directly affects healing and leak rates [5]. | NSFC [5] |
Because instrument-mounted force sensing remains uncommon in clinical robots, a passive suture-based approach has a realistic route to adoption [1][5].
Why it matters
| Potential | What the report suggests | Source |
|---|---|---|
| Quantified force | Knot tension becomes a measurable number [1][5]. | [1][5] |
| Low cost | No sensor hardware; standard instruments apply [2]. | [2] |
| Caution | No clinical outcome data yet [6]. | [6] |
Availability and limits
- This is an editorial summary of a research paper, not a product recommendation [1][2].
- No clinical trial of outcomes has been reported [6].
- Target force differs by tissue and operation [5].
- Residual material and knot profile need evaluation in small spaces [3].
- The device is not commercially available [1].
What to ask before booking
| Question | Why it matters |
|---|---|
| Is this device in clinical use here? | It is a research platform, not a marketed product [1]. |
| How is knot tension controlled in my operation? | Experience currently substitutes for measurement [3]. |
| Which department handles foreign patients, and in what language? | The hospital is a working hospital we do not book; confirm international-department coordination and language support. |
| Does the choice of technique affect my leak risk? | Anastomotic technique matters clinically [5]. |
Questions patients ask
What is Sliputure?
A smart suture that embeds a precisely engineered slipknot beside the surgical knot; untying it releases a preset peak force that gauges how tight the working knot is [1][3].
What problem does it solve?
Force blindness — the loss of direct tactile feedback in laparoscopic and robotic surgery, which makes knot tension hard to judge [3][5].
Where was it published?
Nature, as the cover article on 27 November 2025 [2][4].
Is it available?
No — it is a research result without clinical outcome data or a commercial product [1][6].
Is this relevant to international patients?
It is useful context for China's surgical device research. The hospital is a working hospital we do not book — contact its international department directly [1].